Build Your Own Arduino RTOS — Book Support#
Support site for the (Japanese) book on building a preemptive real-time OS from scratch on the Arduino UNO R4 WiFi.
Note
The book is written in Japanese; this English version of the support site currently covers setup and per-chapter build instructions. Full translations are in progress.
Try It First#
Before any setup, you can run the finished pieces in your browser. No installation and no board needed.
Each chapter’s firmware runs on a virtual board in your browser. The LED
matrix shows CPU usage as bars, and you can type top or kill 3 into the
shell. (The page itself is in Japanese.)
Walk the chapter-13 robot in a physics simulation, with the same neural network that is written to the real board.
To start reading from whatever caught your interest, see Start from what you are curious about.
Contents#
What you need and how to set up Arduino IDE / PlatformIO.
Run the same firmware on your PC when you do not have the board.
Sample code locations, build commands, common pitfalls.
Hardware for the chapter-13 quadruped robot.
Troubleshooting and corrections.
About the Book#
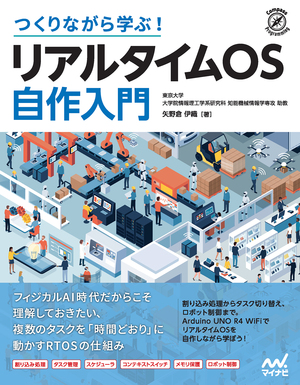
つくりながら学ぶ!リアルタイムOS自作入門 (Japanese edition), by Iori Yanokura, published by Mynavi Publishing on September 18, 2026. ISBN 978-4-8399-9187-6. Available in print and as a PDF.
Free sample (Japanese):
Read sample pages (Mynavi Publishing)
Print:
Amazon.co.jp Rakuten Books Mynavi Books
Also available by ISBN (978-4-8399-9187-6) at Japanese bookstores.
PDF / ebook:
Mynavi Books (PDF) Kindle honto
The Mynavi Books PDF is DRM-watermarked with the buyer’s information and is downloaded from your account page after purchase.